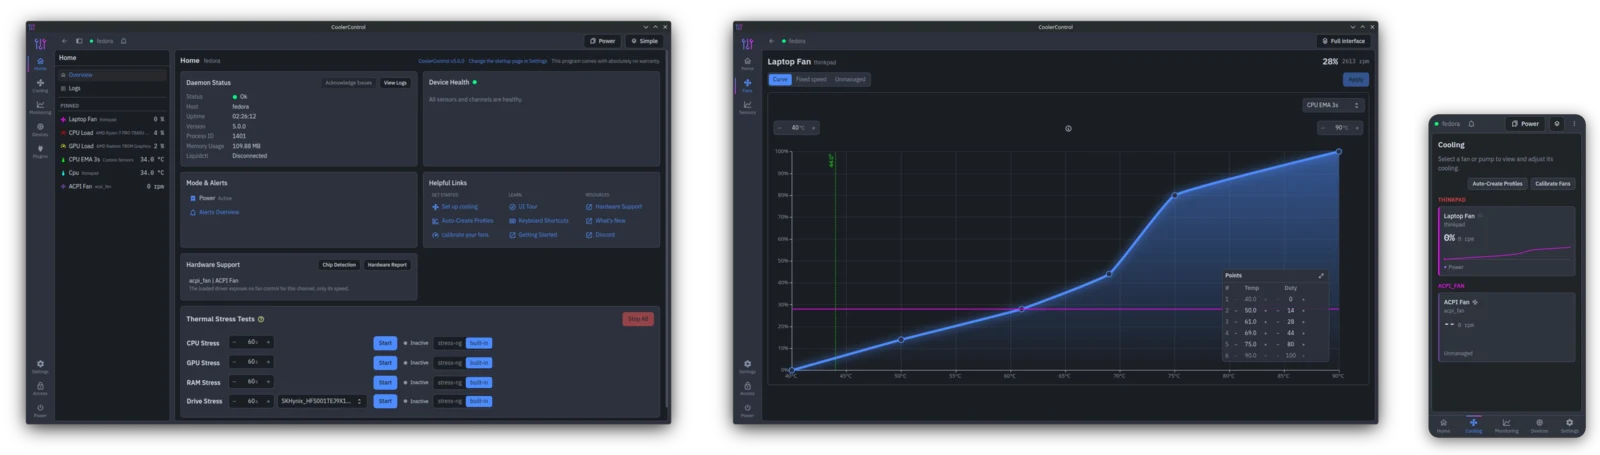
Shortly after version 5.0.0, CoolerControl version 5.0.1 is now available.
CoolerControl is an application for controlling and monitoring fans, pumps and AIO coolers on Linux, with customizable fan curves for CPU and GPU coolers.
The patch brings more resiliency: each device’s IO now runs on its own thread, so a device that stops answering no longer blocks the others, and is instead marked “unreachable” until it comes back on its own. There are also numerous bugfixes, including for multi-socket systems and CPU detection.
Added
- Resiliency: Each device’s IO runs on its own thread, so a device that stops answering can no longer affect other devices. It is marked unreachable and falls back to its failsafe while every other device keeps running, and it returns on its own once it answers again (#609)
- Unreachable is its own device health state in the UI,
/devices/healthand SSE, shown ahead of the failsafe it causes- NVML calls run on a thread per GPU with a time limit, and an NVIDIA GPU that stops answering is reported as unreachable
- liquidctl devices that fail to come back after resume from sleep are reconnected, and if that fails, recovered by restarting coolercontrol-liqctld with a backoff
CC_RUNTIME_DRIVER=epollforces the epoll backend instead of io_uring (#606)- Custom sensors can be added from the Custom Sensors header in the Monitoring and Devices panels
- Plugin manifests accept
argsas an array andenvsas a table, for values containing whitespaceChanged
- Custom sensors opened from Monitoring stay on their chart, with a button to edit the sensor, and the Cooling button on a fan’s chart moved to the name row
- The shutdown reset is capped per device, so a wedged device cannot hold up the others
- A failing duty write is logged when it starts failing and when it recovers, instead of every tick
- The initialized devices log lines list each device with its UID, so two identical devices no longer appear as one
- compio was updated to 0.19, and the minimum supported Rust version is now 1.95
Fixed
- System monitors could show one core at over 90% iowait, or over 90% IO pressure (PSI) for the service, while the daemon was idle. This was a kernel reporting quirk, not real IO or load: since kernel 6.5, a thread sleeping while it waits on io_uring is counted as iowait even though the core is idle, and PSI derives IO pressure from that same flag. The daemon opts out of that accounting on kernel 6.15 and newer. On older kernels the reading is harmless and can be ignored, or
CC_RUNTIME_DRIVER=epollavoids it at the cost of more wakeups (#606)- Interrupted hwmon reads are re-issued instead of failing, and are no longer mistaken for a driver refusing a pwm read (#609)
- Some multi-socket systems, such as a dual-CPU Mac Pro 5,1, got no CPU devices. CPU temps are now matched by coretemp zone and k10temp node, and a CPU that cannot be matched no longer fails CPU initialization
- CPU load is reported per socket again on multi-socket systems
- CPU load, power, temp and frequency channels are no longer left out of a poll when a reading fails or CPUs go offline
- Changing a Function’s response delay did not take effect on a profile shared by several channels until the daemon restarted
- Plugin manifest
argsvalues were mangled, losing characters such as the last one. Fields are now validated and quoted for systemd and OpenRC, and a skipped manifest logs why- An inline
proxy = { ... }table in a plugin manifest was ignored, and an unusable address, port orprivilegedvalue now fails with a message naming the manifest- A plugin working directory containing spaces broke its systemd unit, and the daemon now warns when OpenRC would split an argument containing whitespace
- Corsair HID PSUs could read the reply to an earlier command after resume, failing their reads
- liqctld no longer serves a frozen cached status for a device that has stopped answering, so the failsafe can engage
- PyUSB liquidctl devices logged a hidraw path warning at every startup
- Charts could draw one channel’s values under another channel’s label, scale and color when the set of lines changed
- Unreliable RPM readings could give a calibration a duty floor near 100%, so every duty was written at almost full speed. Flat, inverted and high-floor curves are now flagged as implausible, with a warning, and fall back to a stepped map
- Calibration, profile, alert and shutdown logs name devices and channels by their resolved names, including detected and lm-sensors labels and devices that are no longer present
Security
- NPM dependencies updated to clear advisories
Source: GitLab